RoBétArmé
Autonomous robotic concrete projection.
|
Funded by the European Union. Views and opinions expressed are however those of the author(s) only and do not necessarily reflect those of the European Union or HADEA. Neither the European Union nor the granting authority can be held responsible for them.
|

Autonomous robotic concrete projection.
|
|
Funded by the European Union. Views and opinions expressed are however those of the author(s) only and do not necessarily reflect those of the European Union or HADEA. Neither the European Union nor the granting authority can be held responsible for them.
|
The RoBétArmé project set out to automate tough, labor-intensive tasks in shotcrete application, which involves spraying concrete onto surfaces like walls and tunnels. This process is critical for both constructing new structures and repairing old ones. KU Leuven contributed planning and control methods for both the shotcrete application and the precision finishing of concrete surfaces, including tasks like smoothing and leveling. Backed by the European Commission’s Horizon program, this 42-month project aimed to make shotcreting faster, greener, and more efficient.
Shotcrete Planning and Control
We developed planning and control systems for shotcrete application in harsh environments, where visibility is severely impaired by dust and occlusions [1]. Our team guided the trajectory of the shotcrete nozzle using data-driven approaches that can handle noisy and incomplete observations from cameras. By leveraging techniques like deep reinforcement learning and uncertainty-aware algorithms, we enhanced the precision of the robot’s movements, for accurate concrete spraying even in difficult conditions.
A key aspect of our work was managing the uncertainty that arises from these noisy inputs. We used machine learning models, such as variational inference combined with reinforcement learning, to estimate the most likely state of the environment despite missing or unclear data. This allowed us to make more informed decisions about how to apply the shotcrete efficiently, improving material conservation and reducing waste. Our goal was a robust, adaptive system that can handle the unpredictable nature of construction sites while maintaining high-quality outcomes for both new construction and repair projects.
RA-L Publication: AREPO – Uncertainty-Aware Robot Ensemble Learning Under Extreme Partial Observability
In our first journal publication [2], we asked ourselves how can robots learn effectively in the real world when their vision is noisy, occluded, or incomplete? Our solution introduces AREPO, a reinforcement learning method that quantifies and adapts to uncertainty—unlocking robust decision-making in visually-challenging environments!
✅ Denoised latent representations: We train a VAE to learn, from noisy image inputs, a denoised (latent) representation of the system and a clear and reliable reconstruction of its state.
✅ Uncertainty estimation via Monte Carlo sampling: We quantify epistemic uncertainty by propagating latent variance through the decoder, enabling more informed decision-making.
✅ Uncertainty-guided RL exploration: The estimated uncertainty dynamically modulates maximum entropy RL, prioritizing actions that reduce epistemic uncertainty while improving sample efficiency.
🔬 Results: AREPO achieves state-of-the-art generalization in a high-occlusion industrial task, significantly outperforming standard domain randomization, ensemble RL, and model-based planners in zero-shot sim-to-real transfer.
RSS Publication: ELVIS – Ensemble-Calibrated Latent Imagination for Long-Horizon Visual MPC
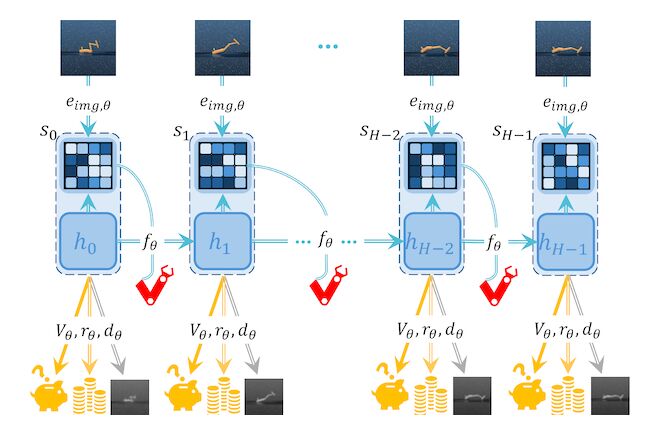
AREPO helps a robot cope with what it cannot see right now. In our next paper [3], we asked how can a robot plan far ahead when its view is blocked? With ELVIS, the robot imagines the outcome of its actions several steps into the future, using a learned model of the world, and picks the most promising course of action. Imagining that far ahead is normally fragile: small prediction errors add up, and when the future can unfold in several ways, planners tend to average them into a single poor plan.
✅ Keeping several plans alive: A multimodal planner (Gaussian-mixture MPPI) maintains multiple coherent plans, rather than collapsing them into one.
✅ Knowing when to stop trusting its imagination: An ensemble of critics estimates how uncertain the robot’s predictions are. ELVIS relies less on look-ahead when that uncertainty is high, before model errors take over.
✅ One objective for learning and planning: The same uncertainty-aware return trains the policy and scores candidate plans, so that the two stay aligned.
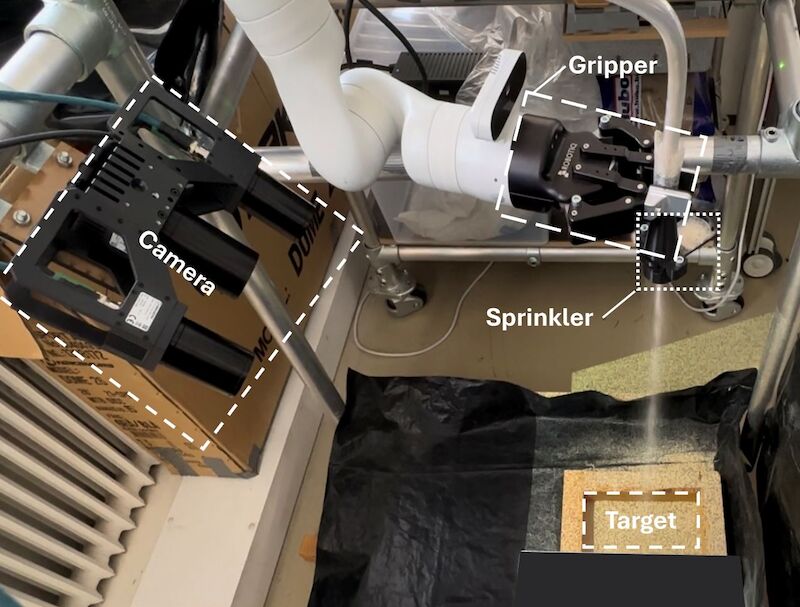
🔬 Results: ELVIS achieves state-of-the-art performance on 14 simulated visual control tasks. It then transfers from simulation to the real world without further training, on a sand-spraying task evaluated the same way as AREPO, a laboratory stand-in for operations where airborne material severely limits visibility. There, it achieves better surface quality than the baselines that lack its uncertainty awareness. Code and videos are on the ELVIS page.
Robot Manipulation of Amorphous Materials
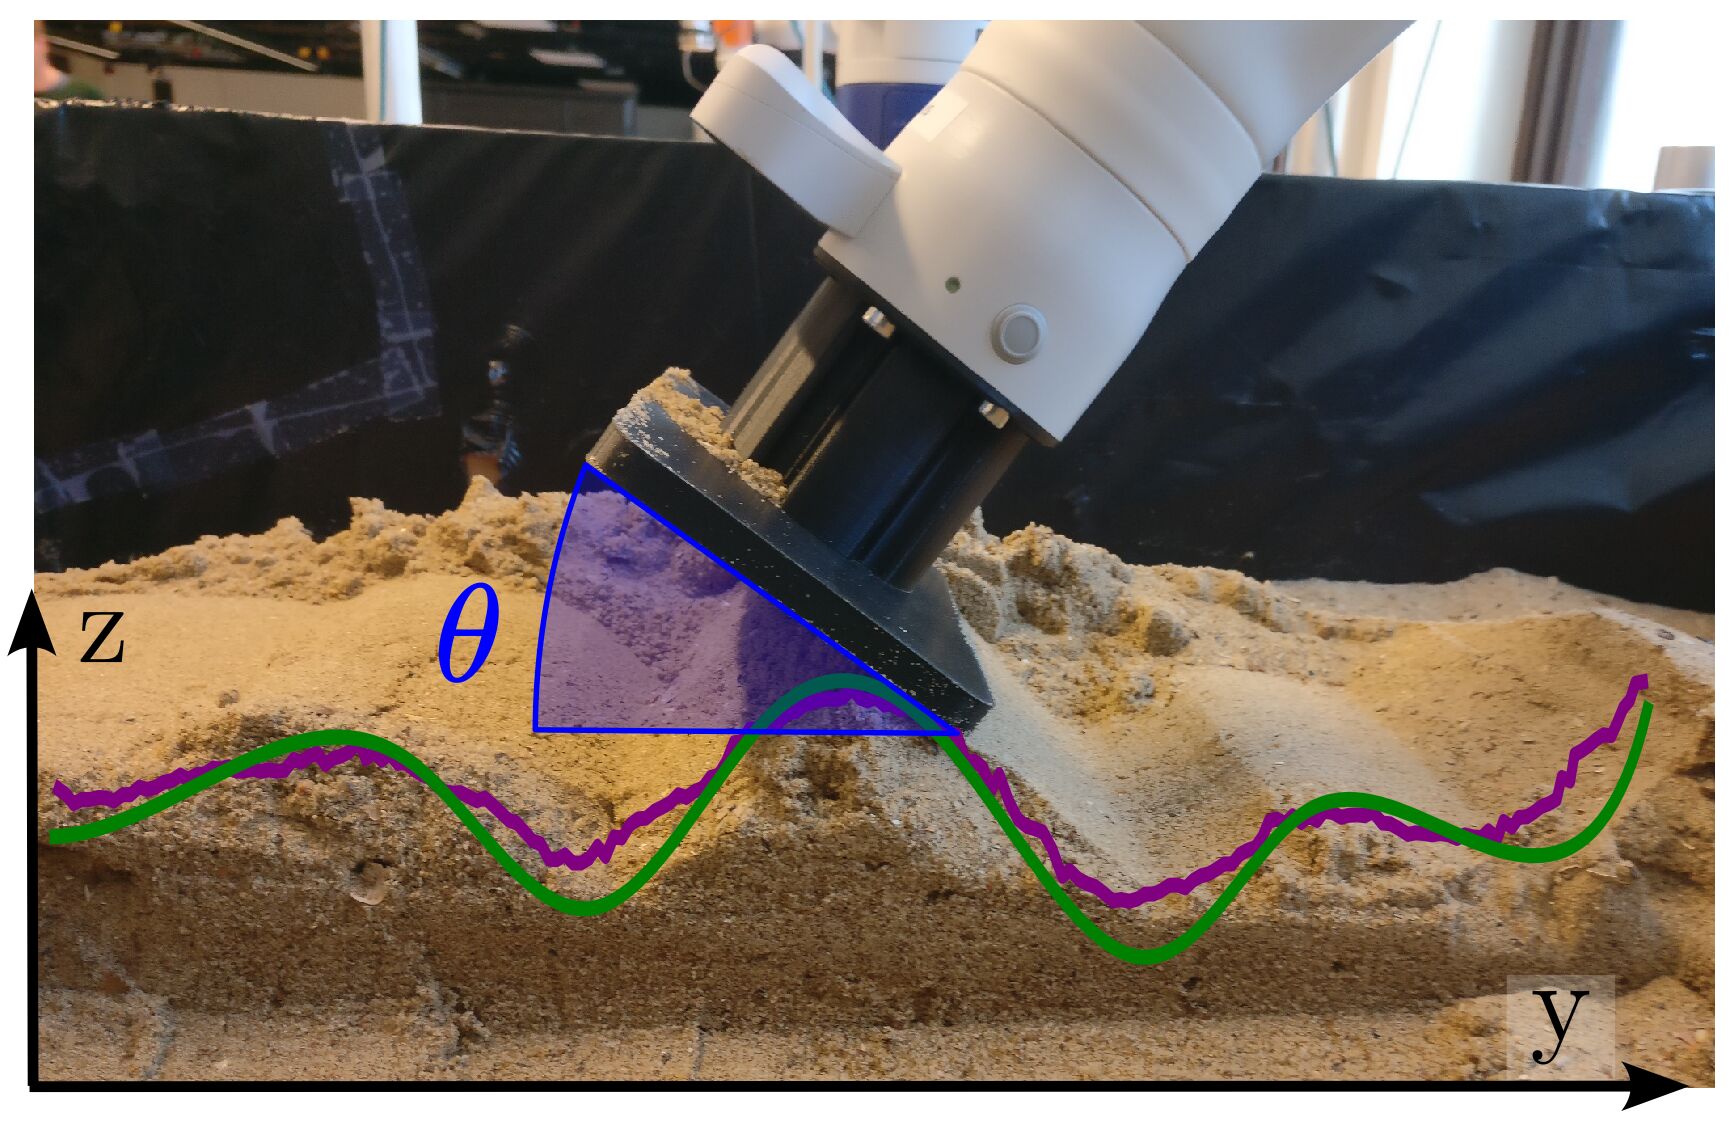
We also developed techniques for smoothing and finishing concrete surfaces after the shotcrete process is completed [4]. Using a robot arm, our system automates the delicate task of leveling and refining the concrete surface to meet the required smoothness. This includes a visual smoothness estimator, which helps the robot assess the surface condition in real-time and adjust its actions accordingly. The robot can adapt its movements based on this feedback, ensuring consistent and high-quality surface finishes, even in challenging environments where human intervention may be limited.
Our approach involved a layered control architecture [4], [5] that integrates perception, control, and task knowledge. By utilizing a combination of skills for surface smoothing, the robot system can execute specific actions like flattening uneven areas or fine-tuning the surface texture. This architecture allows the robot to adapt to the unpredictable nature of concrete as it settles, improving the overall efficiency and precision of the finishing process. Our contribution helps streamline the final stages of shotcrete application. We demonstrated this work on a lab testbed for sand profile grading. The adaptive and iterative capabilities of the robot allow it to approach the desired profile with simple control rules that are effective despite limited knowledge of material behavior.
References
-
 [1]Shotcrete Guidance in Harsh Environments with Uncertainty-Aware Reinforcement Learning.In 4th Workshop on Future of Construction: Safe, Reliable, and Precise Robots in Construction Environments (ICRA 2024 workshop), 2024.
-
[4]Skill-based Layered Control Architecture for the Robotic Manipulation of Amorphous Materials.In 43rd Benelux Meeting on Systems and Control, 2024.
 Bib
 DOI
 PDF
 Video
 arXiv
 Blog